Gantry Welding Robot Workstation for Large Steel Structures
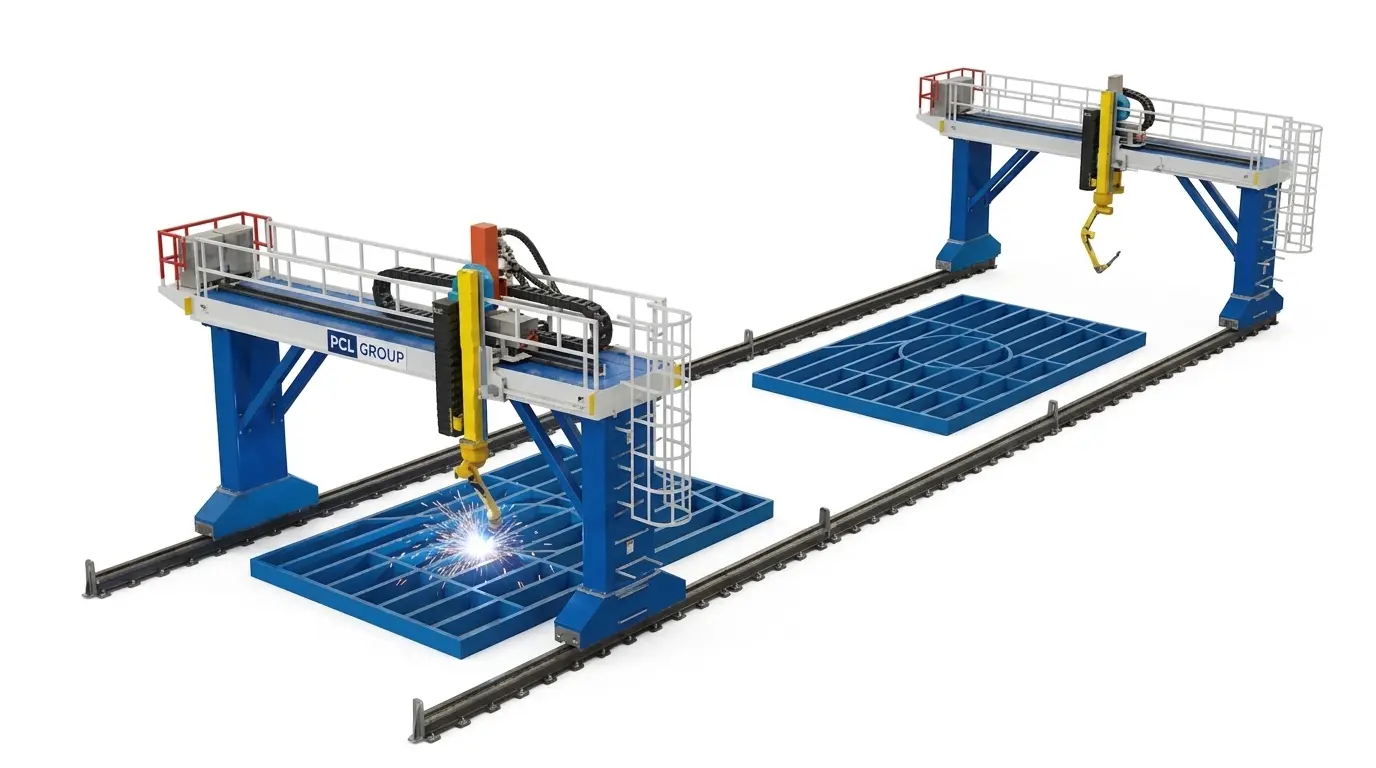
One or two welding robots hung from a gantry that travels on floor rails. The gantry carries the robot over parts far larger than its arm: box girder welding, bridge beams, ship panels and H-beams up to about 20 m long, in one automatic welding cell for steel structure fabricators. Seams are found by 3D vision and laser seam tracking, and paths come from offline programming on your 3D model or from a 3D scan, with no teach pendant programming (teachless, no-programming welding).
- Typical stroke
- 12 x 4 x 2 m
- Part length
- up to ~20 m
- Robots
- 1 or 2
- Processes
- MIG/MAG, tandem
- Delivery
- 20-45 days
How the gantry welding robot works
As a steel structure welding robot for parts too large for a standard cell, the gantry carries a 6-axis welding robot mounted upside down on its beam. The gantry adds three travel axes: X along the rails, Y across the beam and Z up and down. Together they put the torch at the right angle on any seam of a large part, while the floor under the gantry stays free for the crane to bring parts in.
- Load the tacked part with the shop crane.
- Program: generate the path offline from the 3D model, or let the camera scan the part; the software handles weld seam recognition and path planning, and checks the result in a 3D simulation (digital twin) of the cell.
- Locate: laser seam tracking or touch sensing finds the real position of each seam.
- Weld: long seams run continuously, with arc tracking correcting the path as the part heats and moves.
What a gantry welding robot welds: girders, bridge, ship and pontoon structures
- Box girders, box columns and crane beams with stiffeners
- Bridge beams, diaphragms and deck panels
- Ship blocks, double-bottom panels, pontoons and floating docks
- Stiffened plate units
- Long H-beam columns, box column welding and roof beams
- Truck and trailer chassis, railway carriage frames
- Construction machinery structures, tanks and pressure vessels
Weld types: fillet welds (flat, vertical and wrap-around at plate ends), butt and groove welds, lap welds and curved seams. Thick joints are filled with multi-layer, multi-pass welding.
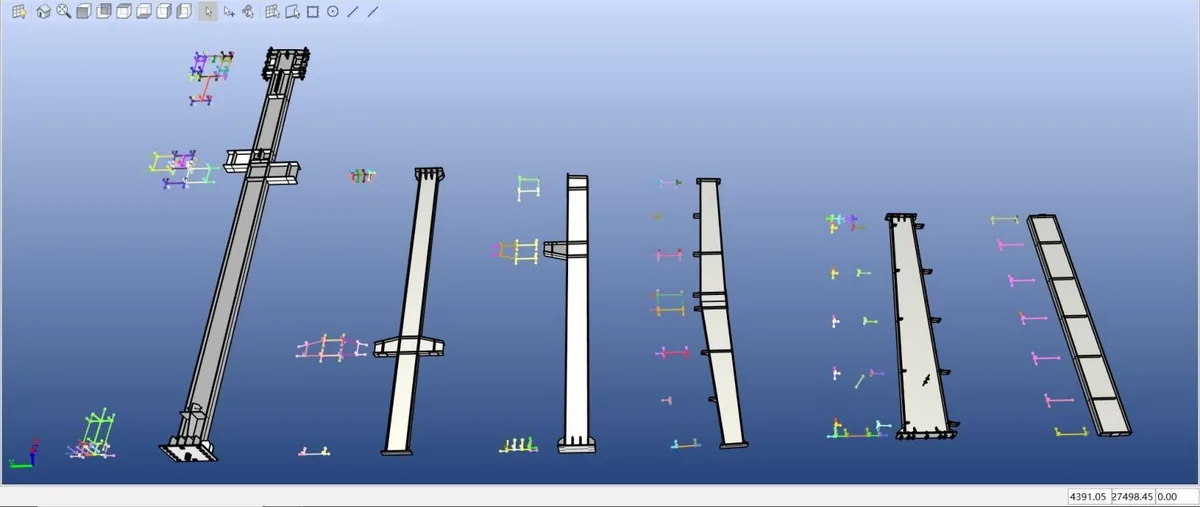
Offline programming or 3D scanning: no teach pendant
From a 3D model
Import the part as STEP, IGS or IFC (Tekla exports IFC). The software reads the seams, matches welding parameters, plans the path and checks the whole path for collisions before the robot moves. A quick scan places the model on the real part.
From a scan, no drawing
For one-off parts or parts without a model. A camera scans the tacked part, the software rebuilds it from the point cloud, finds the seams and plans the path. Several parts on the station can be recognised in one scan.
In both modes the robot locates each seam with the laser before welding. A teach pendant is still there for special welds in tight corners.
Gantry, cantilever, ground rail or welding manipulator
| Layout | Best for | Notes |
|---|---|---|
| Gantry (this machine) | Wide and heavy parts: box girders, ship and bridge panels; two robots on one part | Two rails and a foundation; floor stays clear for crane loading; several stations under one frame |
| Cantilever | Long, open parts up to about 3.5 m wide | One rail, lower cost, one side open for loading |
| Ground rail | Long, narrow parts | Needs the least building height |
| Column and boom welding manipulator | Long straight submerged-arc seams | No robot: one straight seam at a time, no 3D seams or stiffeners |
With two robots on the gantry, both sides of a girder are welded at the same time, which shortens the cycle and keeps heat input balanced to limit distortion. A gantry can also serve two stations: one part is welded while the next is loaded.
Twin robots welding opposite sides balance shrinkage.
One gantry, two stations: the arc keeps running during crane work.
Technical specifications: single and twin robot gantry
| Item | Single robot | Twin robot |
|---|---|---|
| Welding robots | 1 x 6-axis, inverted on the gantry beam | 2 x 6-axis on one beam, collision-protected |
| Gantry span (Y) | 4 m standard, built wider to suit the part | |
| Rail length (X) | 12 m standard, extendable; beams of about 20 m in one pass | |
| Lift (Z) | 2 m standard | |
| Drive | Precision rack and pinion, AC servo motors on every axis | |
| Power source | 1 x 500 A digital inverter, 100% duty cycle | 2 x 500 A digital inverter, 100% duty cycle |
| Welding torch | 550 A liquid-cooled robot torch | |
| Seam finding | 3D line laser seam camera, wire touch sensing, arc tracking | |
| Drawing-free scanning | Large-field 3D scan camera (optional) | |
| Programming | Offline from STEP / IGS / IFC models, or teaching-free from a scan; teach pendant included | |
| Processes | MIG/MAG DC and pulse, solid and flux-cored wire; TIG and tandem twin-wire optional | |
| Typical welding speed | 0.3-0.6 m/min (fillet welds, by leg size) | 0.3-0.6 m/min per robot, two seams at once |
| Power source brands | Megmeet standard; Aotai, Panasonic, Lincoln Electric, Miller on request | |
| Welding procedures | Can be qualified to ISO, AWS D1.1 and ABS, LR, CCS rules | |
| Certification | CE, ISO 9001 | |
| Delivery | 20-45 days, depending on size and options | |
Every gantry is sized to the customer’s parts, so span, rail length, lift and the number of robots are confirmed in the layout drawing before you order.
Vision system
Two cameras do different jobs. The scan camera sees the whole station from above and finds the parts. The seam camera on the torch then measures each joint close up, so the robot welds where the seam really is, not where the drawing says it should be.
| Item | Large-field scan camera | Seam camera (on the torch) |
|---|---|---|
| Job | Find parts, rebuild them as a point cloud | Locate and track each seam |
| Working distance | 2,000-4,000 mm | 300-800 mm |
| Field of view | 1,750 x 2,800 mm near, 3,000 x 5,000 mm far | 460 x 290 mm near, 1,150 x 680 mm far |
| Precision | Z ±0.5 mm at 2 m | 0.02 mm repeatability, 0.35 mm accuracy at 300 mm |
| Scan rate | 6,000 lines/s | 3,000 lines/s |
| Ambient light tolerance | 180,000 lux | 480,000 lux |
| Laser / protection | Blue 450 nm, IP65 | Blue 450 nm, IP65 |
Common welding problems and how the gantry solves them
| Problem on a manual line | What the gantry robot does |
|---|---|
| Not enough skilled welders | One operator loads parts and runs one or two robots; the welding knowledge sits in the parameter database |
| Long seams stopped and restarted | Seams of 10-20 m run continuously; arc restart with rollback if the wire or gas runs out |
| Fit-up gaps vary from part to part | Laser and arc tracking correct the path seam by seam |
| Distortion on long girders | Twin robots weld both sides at once to balance heat input; fixed welding sequence every time |
| Programming takes longer than welding | Paths come from the Tekla model or a scan in minutes; no point-by-point teaching |
| Crane waits while parts are moved | The robot travels to the seam; the part stays put. Two stations under one gantry keep the robot busy while the next part is loaded |
Send a STEP model: what our engineering evaluation covers
For a new product, the assembly sequence decides how much of the welding a robot can do. Send the STEP model and your planned assembly and welding sequence. We run a robotic welding simulation of reachability and collisions, and where a different sequence raises the automation level, we propose it.
What the evaluation reports
- Robot accessibility and reachability for every seam
- Number and percentage of welds the robot can make, and the welds left for manual welding
- Welds made while the structure is still open, separated from the closing welds made after the deck or cover plate is fitted
- Dual-robot allocation, where two robots pay off
- Collision avoidance along every path
- Welding positions and workpiece handling, turning or repositioning
- Heat input, welding sequence and distortion control
- Fixtures and workpiece positioning needed
- Estimated cycle time and overall production efficiency
How we raise the robotic share
- Keep the structure open longer: weld bottom plates, internal frames, bulkheads and walls before the deck goes on, so most internal seams are reachable from above.
- Prefabricate separately: weld the deck or cover plate as its own sub-assembly on the same station.
- Leave only closing welds: the welds that can only be made after closing are listed separately, for robot or manual welding.
- Split long tracks: for very long parts, two units of about 13 m each keep travel accuracy and speed better than one 26 m track, and they can weld at the same time.
- Balance the heat: symmetric sequences and two robots welding opposite sides reduce distortion.
Typical products: pontoons and floating docks, ship blocks and double-bottom panels, bridge deck panels, box girders, columns and crane beams for serial production.
Gantry welding robot ROI: estimate your payback
Enter the system price to see the payback period.
A simple estimate from labour savings only. Gains from faster throughput and less rework are not included.
Welding process and weld quality
On long structural seams, weld quality depends on holding torch angle, stick-out and travel speed constant from the first metre to the last. In automated welding these stay fixed along a 12 m seam, so penetration, bead shape and heat input stay even.
3D scanning and seam tracking
Vision-guided welding works in two steps. A large-field 3D scan finds each part and builds a point cloud, then a 3D line laser camera on the torch measures every joint close up: position, gap and groove shape. This laser vision step is what makes weld seam recognition reliable on real, tacked parts. During welding, arc tracking (through-the-arc seam tracking) follows the joint as the plate heats and moves. Wire touch sensing is available as a backup on shiny or painted surfaces.
Penetration and fusion
Penetration depends on current, voltage, travel speed, torch angle and stick-out. The gantry robot holds all five constant and the seam camera keeps the torch on the root, so lack of fusion at the root or toe is far less likely than with manual welding on long seams. Pulse MAG with mixed gas gives good side-wall fusion with little spatter; DC spray transfer gives the deepest penetration on thick fillet and groove welds.
Multi-layer, multi-pass welding
For large fillet welds and groove (bevel) welds, the software lays out the passes from the joint size: root pass, fill passes and cap pass, each with its own offset, weave and parameters. Arc tracking shifts each pass to the real joint. Complete joint penetration (CJP) and partial joint penetration (PJP) groove welds follow the groove preparation and backing in your procedure.
Wire and shielding gas
- Solid wire 1.0-1.6 mm, 1.2 mm most common (ER70S-6 / G3Si1 for carbon steel)
- Flux-cored wire 1.2-1.4 mm for higher deposition and positional welds
- Mixed gas 80% Ar / 20% CO2 (M21) for pulse and spray transfer with low spatter
- 100% CO2 for lower gas cost where spatter is acceptable
- Stainless steel with matching wire and Ar-rich gas
Heat input and distortion
Heat input (kJ/mm) = voltage x current x 60 / (travel speed in mm/min x 1000). Because the robot never changes speed or pauses mid-seam, heat input stays inside the procedure limits, and a fixed welding sequence repeats the same shrinkage on every beam. Preheat and interpass temperature still follow your WPS.
Standards and procedures
The robot welds to your welding procedure specification (WPS). Procedures can be qualified (PQR) to AWS D1.1, ISO 15614-1 and ship classification rules, and the station fits shops working under EN 1090 and ISO 3834. Every parameter set is stored in the database, so a qualified procedure is repeated exactly.
Typical MAG fillet weld parameters
Starting values for horizontal fillet welds, 1.2 mm solid wire, 80% Ar / 20% CO2. Final values come from your procedure qualification.
| Leg size | Passes | Current | Voltage | Travel speed |
|---|---|---|---|---|
| 6 mm | 1 | 260-300 A | 28-31 V | 40-55 cm/min |
| 8 mm | 1 with weave, or 2 | 280-320 A | 29-32 V | 30-45 cm/min |
| 10 mm | 3 | 280-320 A | 29-32 V | 35-50 cm/min per pass |
| 12 mm | 4-6 | 280-320 A | 29-32 V | 35-50 cm/min per pass |
Welding functions
- MIG/MAG welding, DC and pulse, solid and flux-cored wire
- Tandem twin-wire welding for thick plate (optional)
- Weave patterns: sine, triangle, arc, V and pendulum
- Laser positioning, laser scanning and laser seam tracking
- Wire touch sensing
- Arc tracking with multi-layer, multi-pass welding
- Arc restart with path rollback after an interruption
- Stitch (intermittent) welding
- Collision checking along the full path, including between two robots
- Automatic torch cleaning station
Gantry welding robot videos


Installation and service
What your shop provides
- Floor space for the rails and a fenced safety zone
- A foundation for the rails, to our drawing
- Crane access for loading and unloading parts
- Three-phase power, shielding gas and dry compressed air
- Fume extraction over the welding area
What we provide
- Layout drawing with foundation loads before you order
- Export packing and shipping
- On-site installation, commissioning and operator training (quoted per project)
- Remote support by WhatsApp, video and remote desktop
- Spare parts and consumables: contact tips, nozzles, liners
Maintenance and safety
| Interval | Task |
|---|---|
| Daily | Check nozzle, contact tip, wire feed and gas flow; the torch cleaner reams the nozzle between seams |
| Weekly | Inspect torch cables, hoses and the camera window |
| Monthly | Lubricate racks, pinions and linear guides; check camera calibration |
| Yearly | Check rail alignment and servo drives; update the controller software |
Safety: fenced cell with interlocked gates, light curtains between stations, emergency stops on the gantry and the operator desk, collision checking before every program and fume extraction over the welding zone.
Other PCL welding systems
| System | Best for |
|---|---|
| Gantry welding robot (this page) | Wide, long and heavy structural parts |
| Cantilever welding robot workstation | Long structural parts up to 3.5 m wide, teaching-free programming |
| Robotic welding station with positioner | Repeat batches of medium parts that need turning |
| AGV welding robot | Parts too large to move, such as tanks and hulls |
| Cobot welding machine | Small batches and short changeovers |
| H-beam production line | Assembling, submerged-arc welding and straightening built-up H-beams |
For a complete line, from cutting to welding, see cutting and welding solutions and steel structure equipment.
Frequently asked questions
What is a gantry welding robot?
It is an industrial welding robot hung upside down from a gantry frame that travels on two floor rails. The gantry moves the robot along the part (X), across it (Y) and up and down (Z), so one robot can weld seams on parts many times larger than its own reach.
How large a part can the gantry weld?
The frame is built to your parts. A typical stroke is 12 m x 4 m x 2 m (X x Y x Z), and longer rails let the gantry weld beams of about 20 m in one pass. Tell us your largest part and we size the gantry to it.
Gantry or cantilever: which do I need?
A cantilever runs on one rail and reaches over the part from one side, which suits long parts up to about 3.5 m wide. A gantry spans the part on two rails, so it handles wider parts such as box girders, ship panels and bridge sections, can carry two robots on one beam and can serve several stations under one frame.
Can one gantry carry two robots?
Yes. Two robots on one gantry can weld the same part from both sides, which also helps balance heat input and distortion, or they can work on two stations while parts are loaded and unloaded.
Do I need to teach every weld?
No. Paths can be generated offline from your 3D model, or with the teaching-free package a camera scans the tacked part and the software finds the seams. Laser seam tracking or arc sensing then corrects each seam for fit-up variation before and during welding. A teach pendant stays available for special welds.
Which welding processes are supported?
MIG/MAG with solid or flux-cored wire is standard, in DC and pulse modes. TIG and tandem twin-wire welding for thick plate are available, and multi-layer, multi-pass welding is supported for heavy joints.
Which welding power sources can be used?
Megmeet, Aotai, Panasonic, Lincoln Electric or Miller, or another brand you already use. Matching your existing brand keeps spare parts and welder know-how in one system.
What does the building need?
Floor space for the rails plus a safety zone, a foundation able to carry the gantry rails, crane access for loading parts, a three-phase power supply, shielding gas and compressed air. We send a layout drawing with foundation loads before you order.
How fast does it weld?
Typical travel speed is 0.3-0.6 m/min per robot on fillet welds, depending on leg size and position. The bigger gain is arc-on time: the robot does not stop to reposition, change hands or wait for the crane, and a twin-robot gantry welds two seams at once.
How is the gantry maintained?
Daily checks of nozzle, contact tip, wire feed and gas flow; weekly checks of cables and hoses; monthly lubrication of racks, pinions and guides; a yearly rail alignment and drive check. The automatic torch cleaner handles nozzle spatter between seams.
How long is delivery?
20 to 45 days depending on the stroke, the number of robots and the options. The confirmed date is in the quotation.
How does the robot control weld penetration?
Penetration is set by current, voltage, travel speed, torch angle and stick-out. The robot keeps all five constant along the seam, and the 3D seam camera and arc tracking keep the torch on the joint root, so penetration stays even from one end of the beam to the other. For deeper penetration on thick joints, DC spray transfer and multi-pass welding are used.
Which wire and shielding gas should I use?
For carbon steel, 1.2 mm solid wire (ER70S-6 / G3Si1) with 80% Ar / 20% CO2 mixed gas is the usual choice: stable pulse and spray transfer with little spatter. 100% CO2 lowers gas cost but adds spatter. Flux-cored wire gives higher deposition. Stainless steel uses matching wire and Ar-rich gas.
Can it weld groove welds and full penetration joints?
Yes. Groove (bevel) welds are filled with multi-layer, multi-pass welding: root, fill and cap passes laid out from the joint size, with arc tracking correcting each pass. Complete and partial joint penetration welds follow the groove preparation and backing given in your welding procedure.
Can welds be qualified to AWS D1.1 or EN 1090?
The robot welds to your WPS. Procedures can be qualified to AWS D1.1, ISO 15614-1 or class society rules, and the station suits shops certified to EN 1090 and ISO 3834. Stored parameter sets mean a qualified procedure is repeated exactly.
How much does a robotic welding system cost?
The welding robot price depends on the layout and size (track or span length), the number of robots, the vision package, the welding power source brand and on-site service. Send your largest part size and production volume and we quote the exact configuration.
Can you evaluate my part from a STEP model?
Yes. Send the STEP model and, if you have one, your planned assembly and welding sequence. We simulate reachability and collisions, report how many welds the robot can make and which stay manual, separate open-structure welds from closing welds, and estimate cycle time. Where a different assembly sequence gives a higher robotic share or less distortion, we propose it.
Is a longer track always better?
No. Very long single tracks cost accuracy and speed. For parts around 26 m we usually recommend two units of about 13 m each: they hold accuracy better, can weld at the same time, and can also run as two separate stations.
Get a gantry layout and quotation
Send your part data and we reply with a layout drawing, the right span and number of robots, and a price.
- Largest part: length, width, height
- Plate thickness and weld types
- Parts per shift and building size
- Drawings or Tekla models, if available